Mechanical Engineer · Phoenix, AZ

I design and build things that move.

Electromechanical Systems & Product Design

I take hardware from early requirements through parametric CAD, prototyping, fabrication, assembly, testing, and revision — CNC-machined and sheet-metal structures, 3D-printed components, fixtures, robotic platforms, and the electronics that go inside them. I design for the shop as much as for the spec.

Parametric CAD DFM / DFA GD&T & detail drawings CNC & sheet metal Fixtures & tooling FEA & hand calcs Hardware integration Embedded control
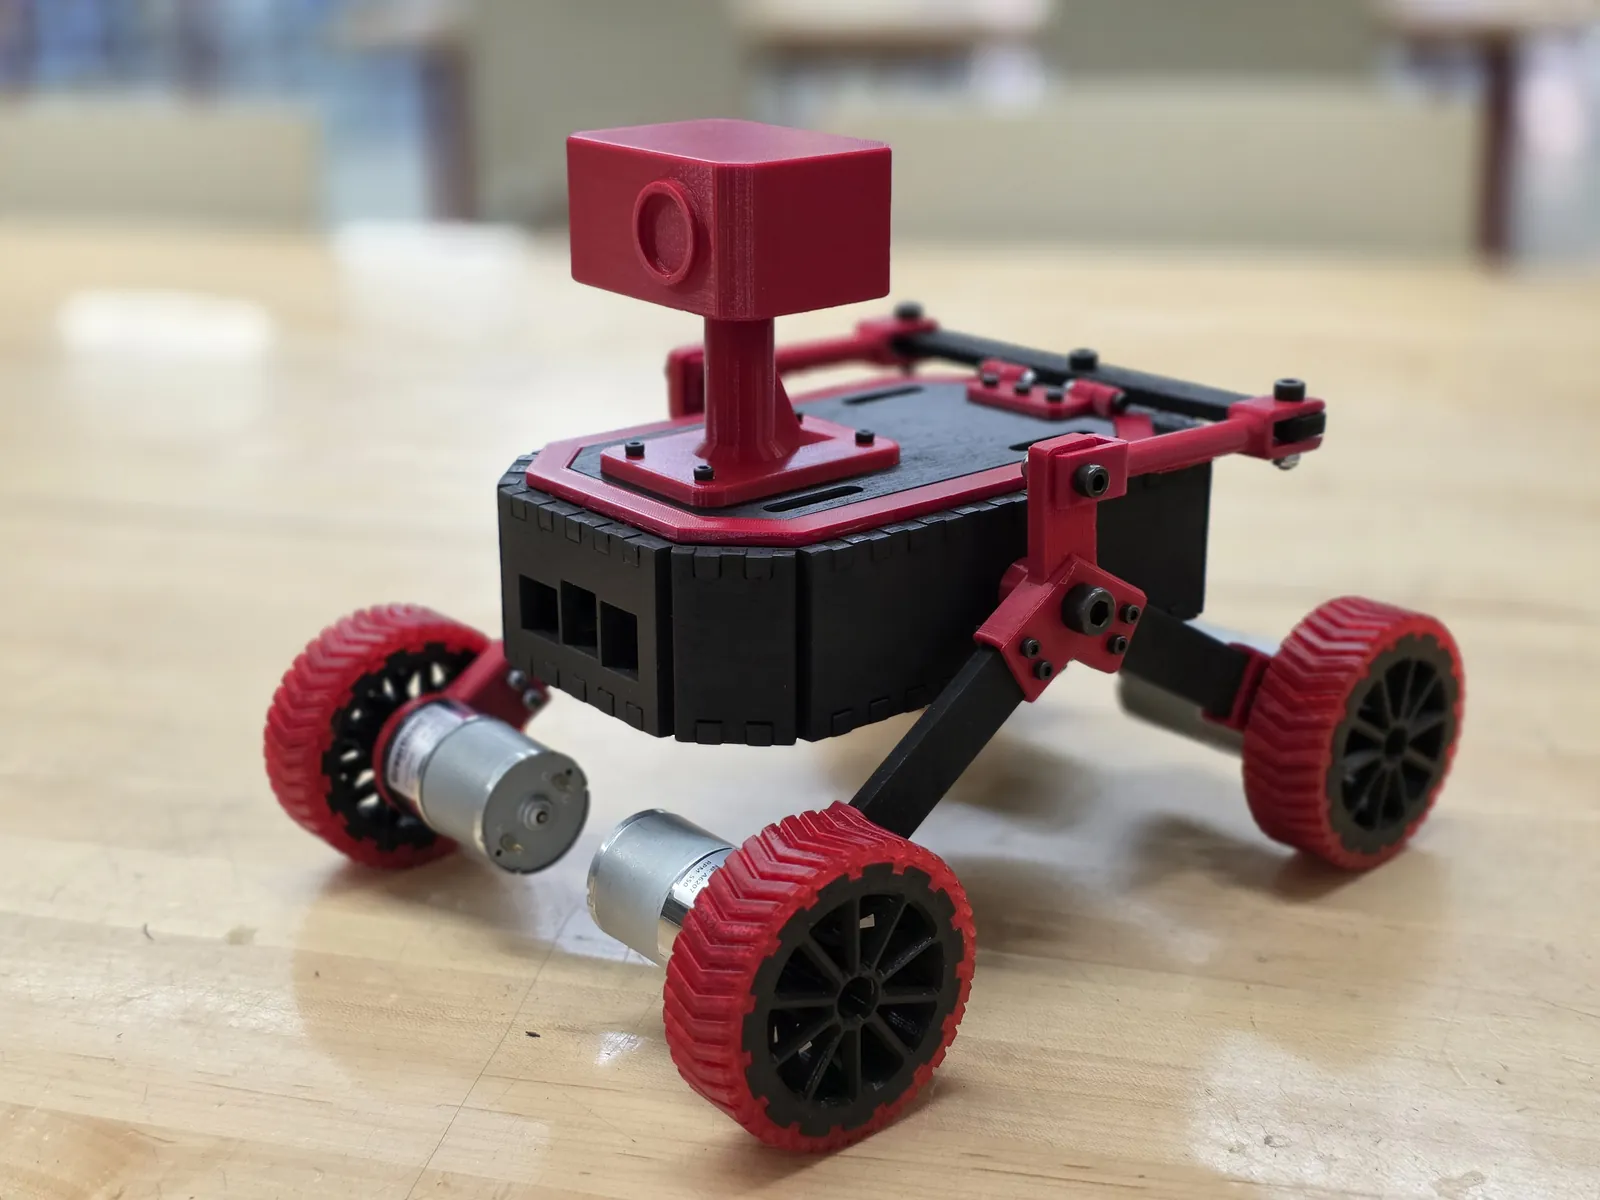
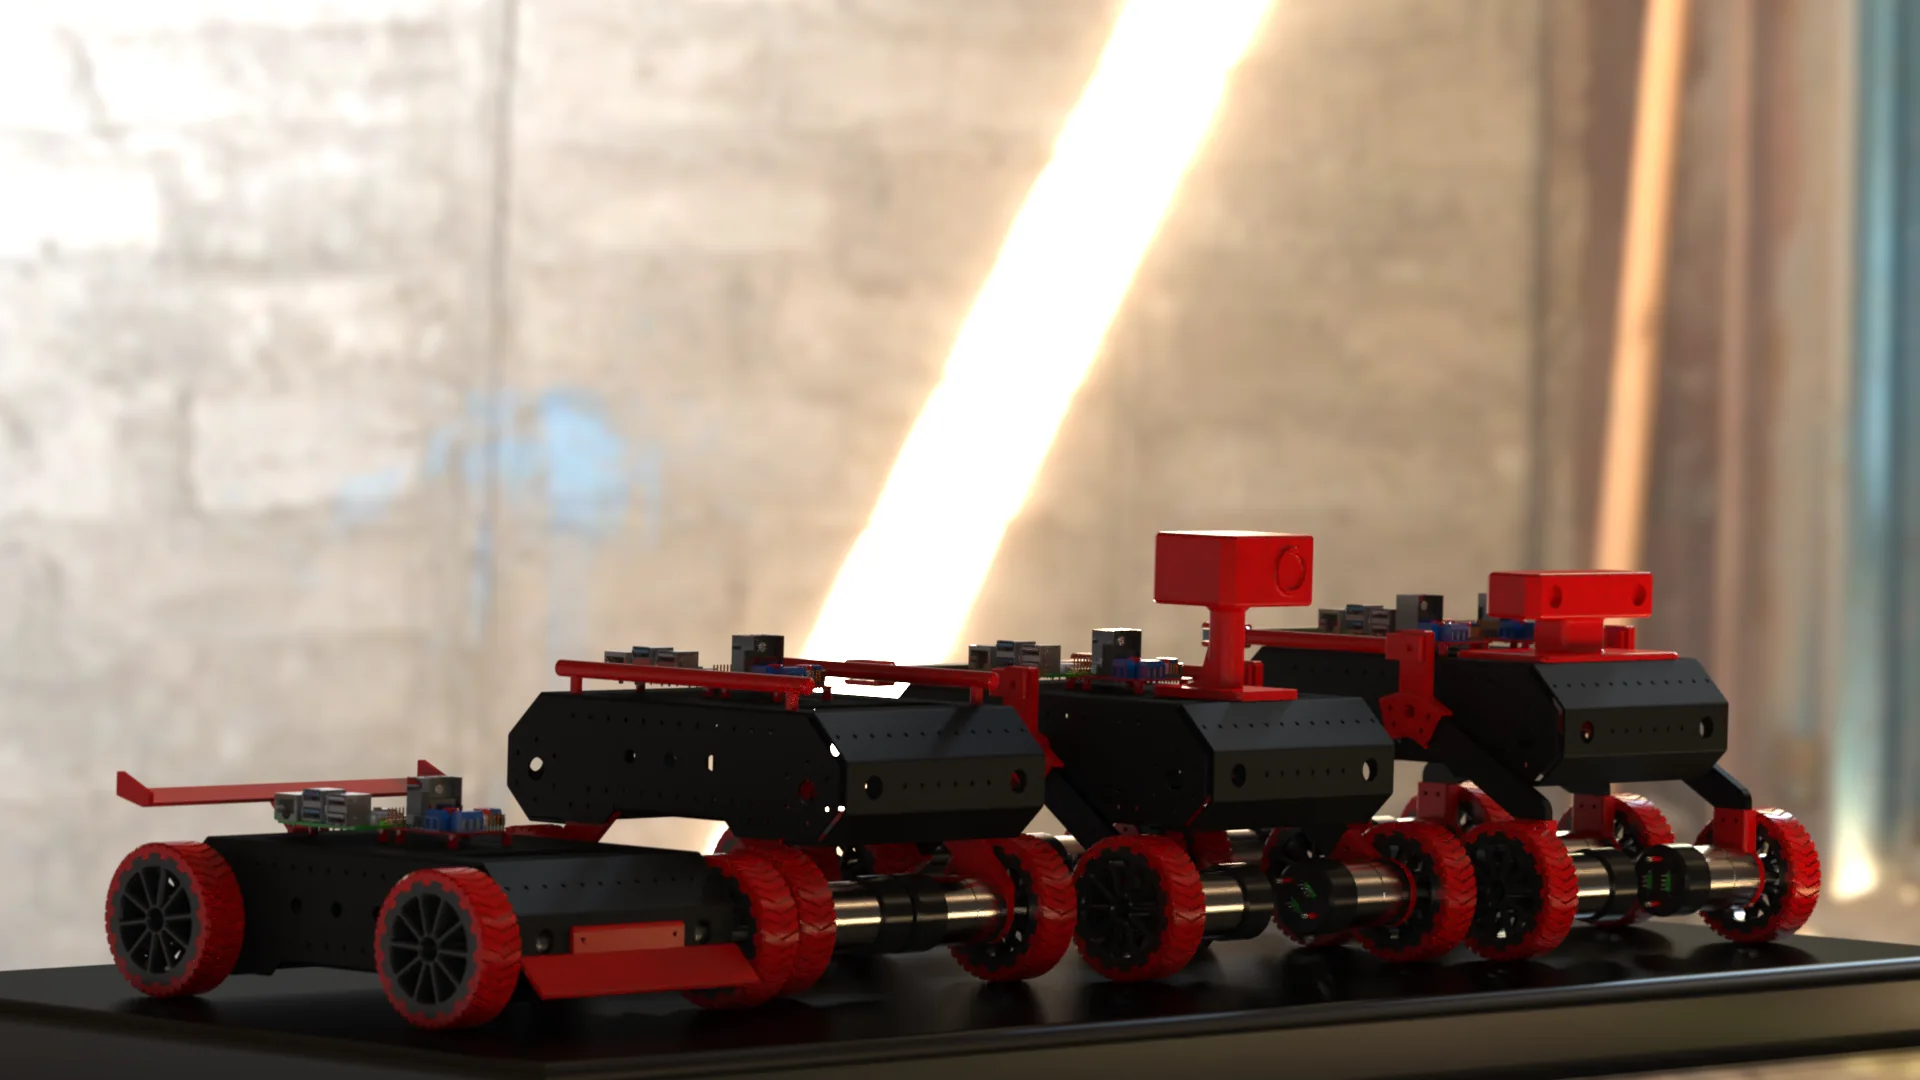
Three generations of the NOMAD educational rover platform, rendered side by side
NOMAD · three generations of the educational rover platform

Selected work

Four in depth · three in brief
Mars Rover

SDRC Full-Scale Mars Rover

Build a full-scale rover that could cross rough terrain and manipulate objects, with no prior platform to build from.

  • Led a 15+ member mechanical, electrical, and software team through the 2026 University Rover Challenge build, owning CAD architecture, interface definition, detail drawings, a ~$10K BOM, and the design reviews that held fabrication to schedule.
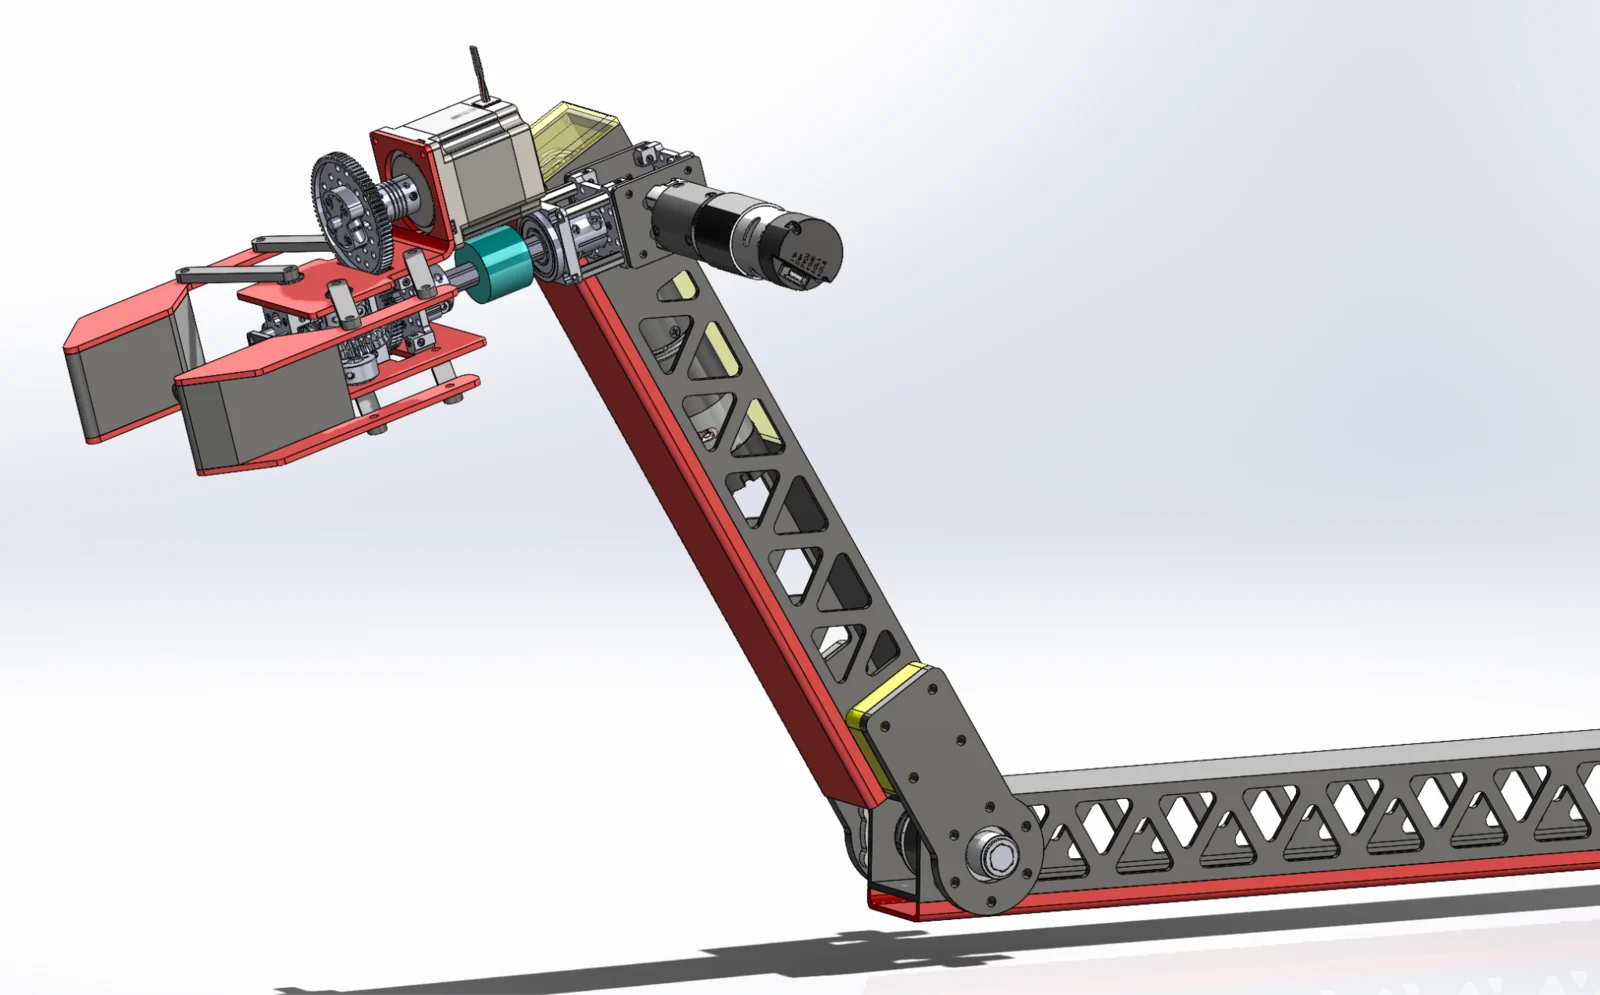
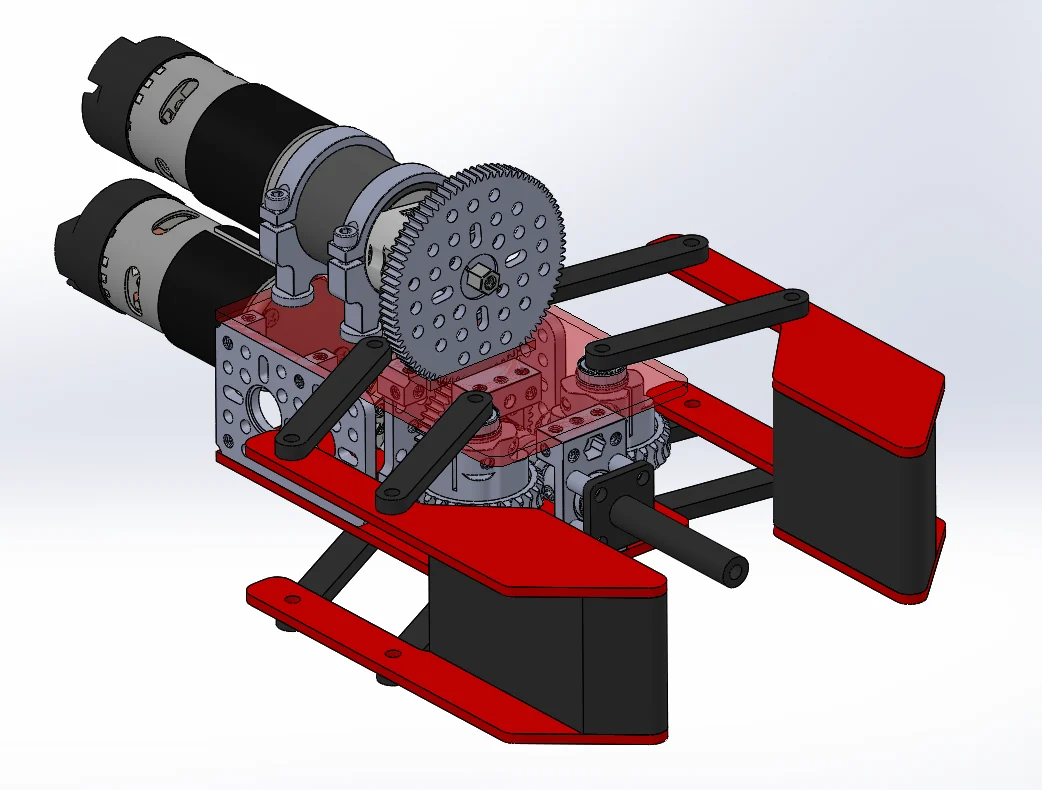
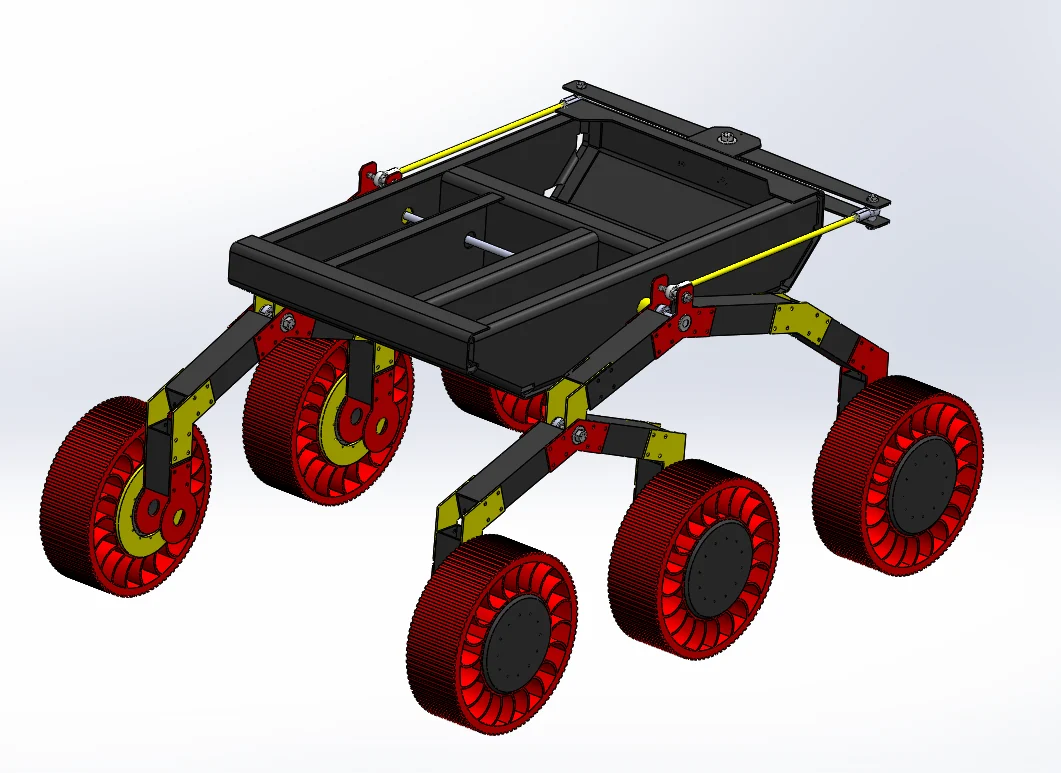
  • Owned mechanical architecture in SolidWorks across suspension geometry, drivetrain packaging, structural chassis, and a multi-DOF arm and end effector — sizing joints around reach envelope, actuation, and rigidity under load.
  • Selected integrated BLDC hub motors against torque, packaging, and CAN compatibility, then sized wheel diameter around the motors' fixed internal gear ratio to meet target speed and grade-climbing performance.
  • Designed the sheet metal chassis with flat patterns and bend allowances built for vendor laser cutting, working with machining and drivetrain suppliers on part specifications and process capability.
RolePresident & Lead Mechanical Engineer
Team15+ across mechanical, electrical, software
Years2023 – 2026
ToolsSolidWorks · CAN bus · Sheet metal · BLDC drivetrain
Rover chassis, suspension and drivetrain CAD assembly
Multi-DOF robotic arm CAD
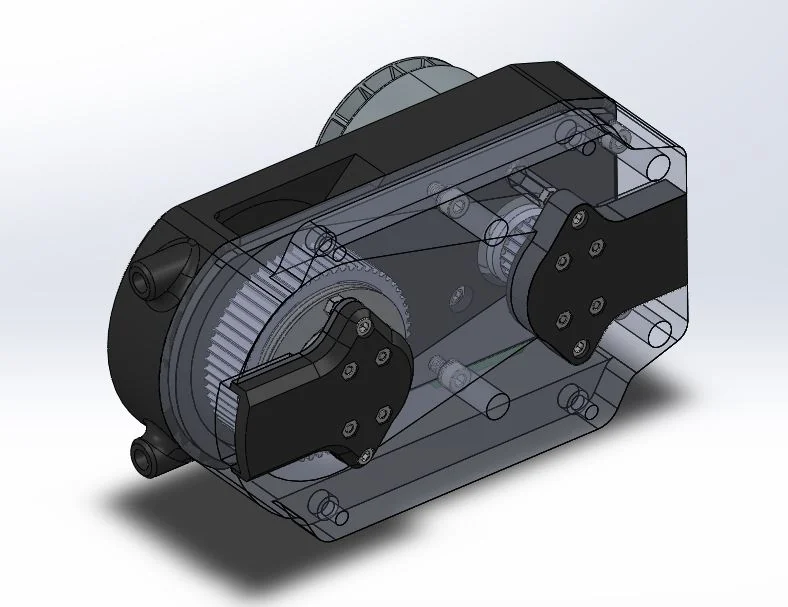
Rover end effector CAD
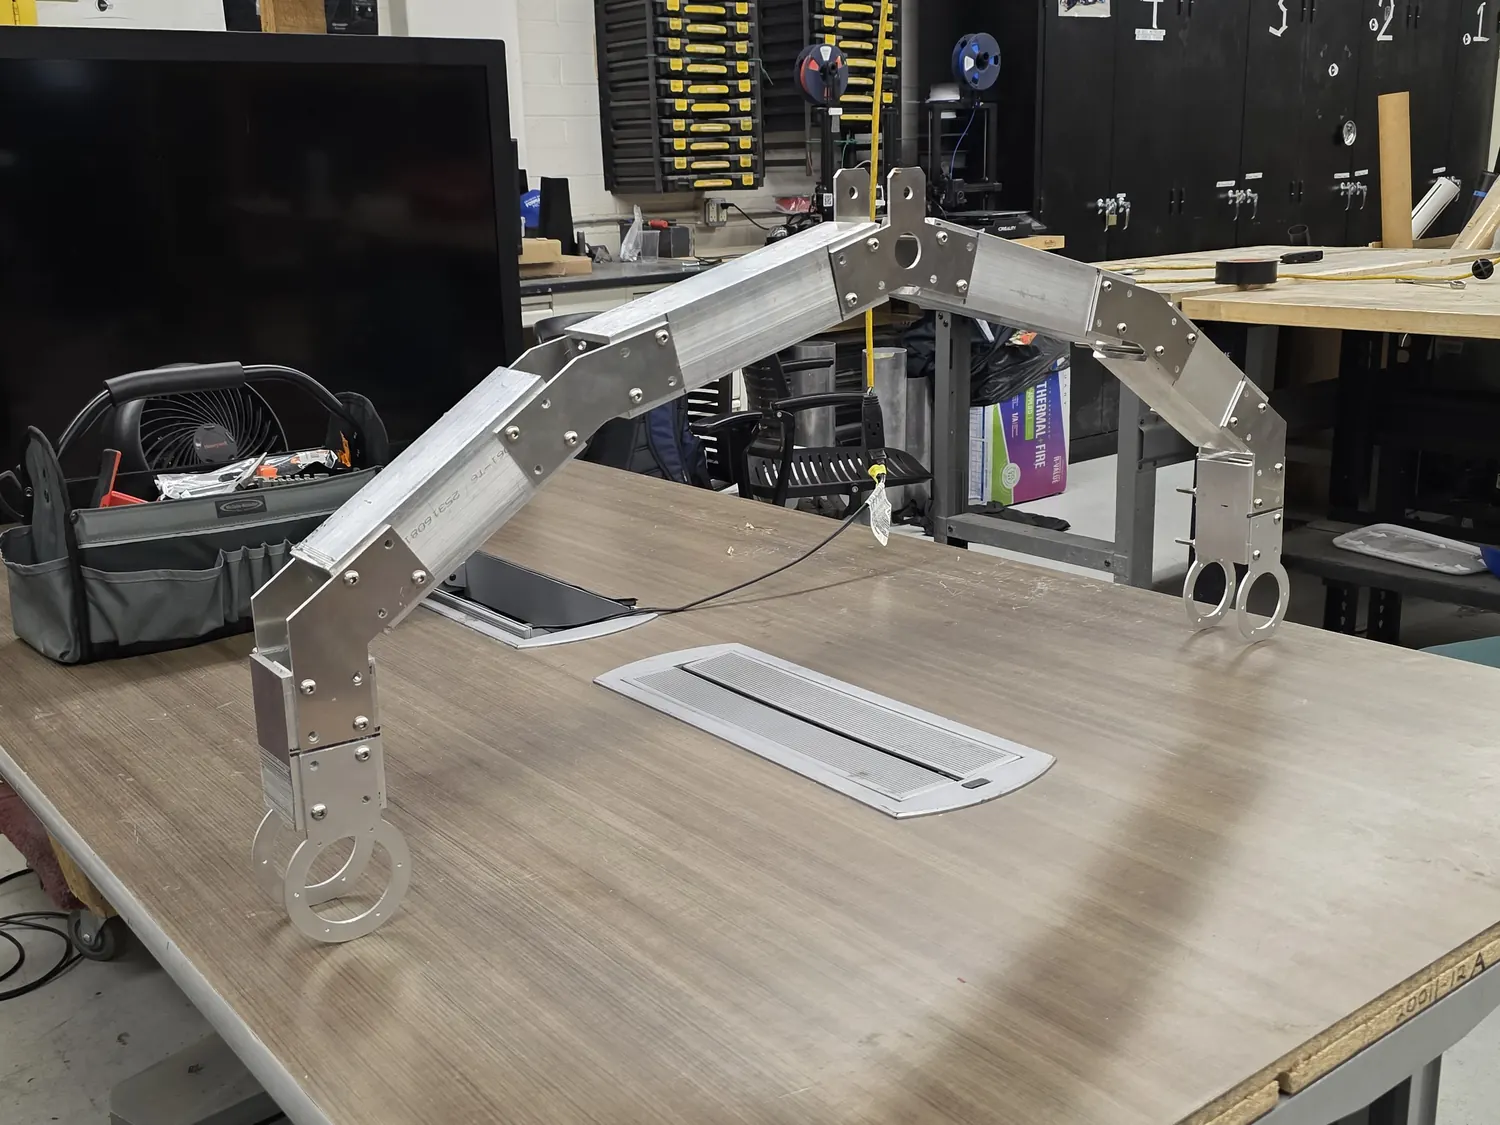
Rover arm assembly on the bench during integration
Product Design

NOMAD Educational Robotics Platform

Put a working rover platform in the hands of 40+ students who had never assembled hardware.

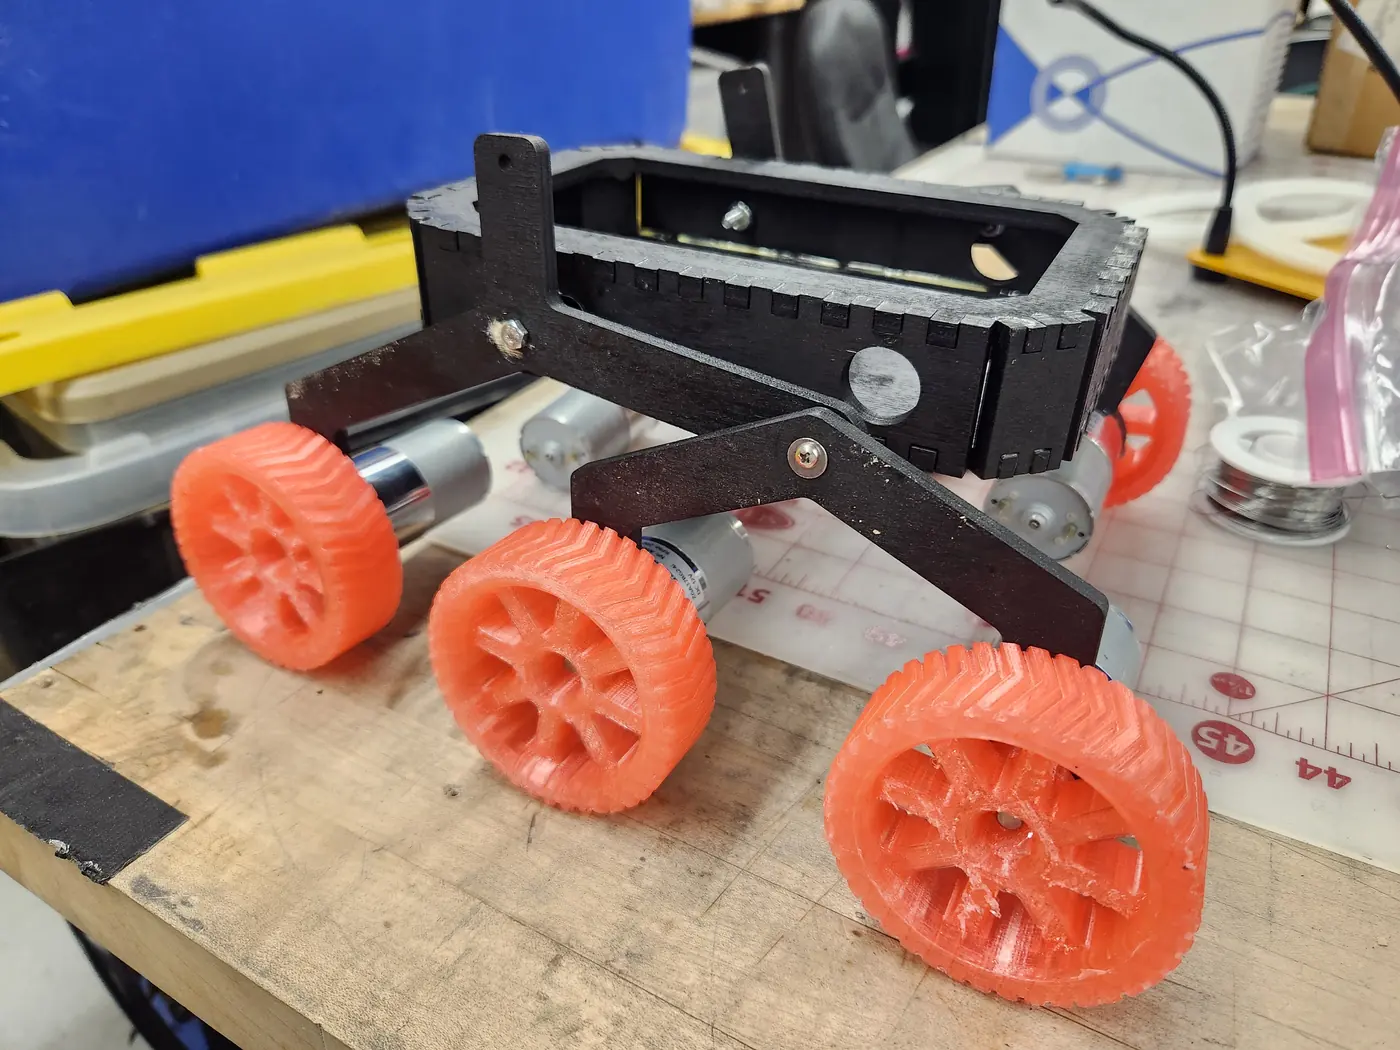
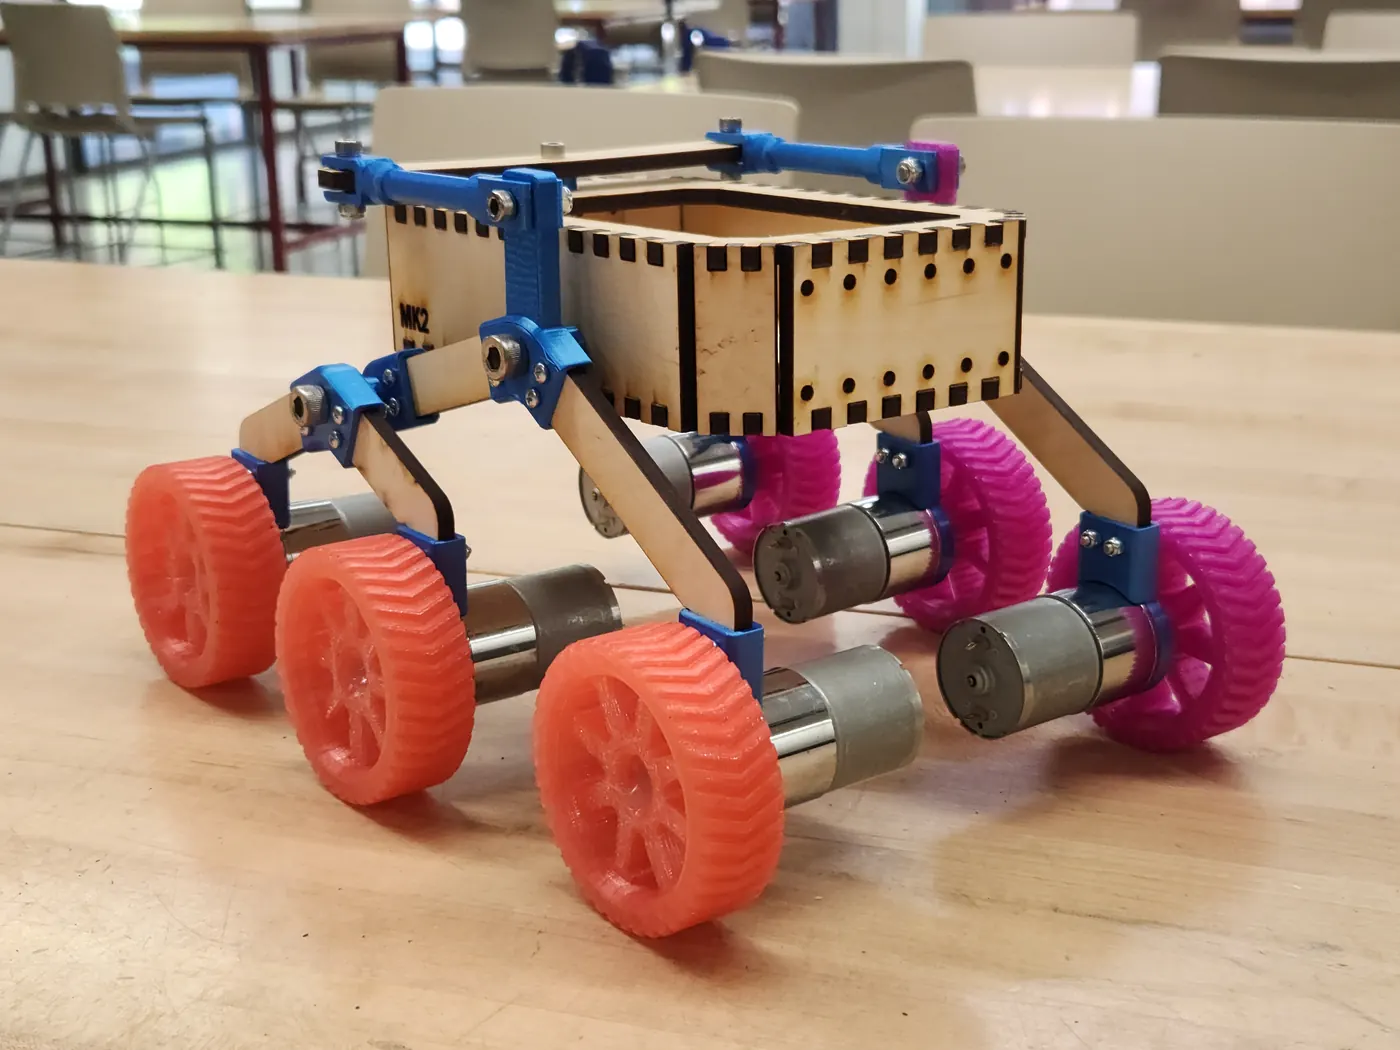
  • Designed a modular Raspberry Pi rover platform across three production generations — Rusty, RoZ, and Norm — reworking geometry each cycle to improve structural stability, electronics packaging, and manufacturability.
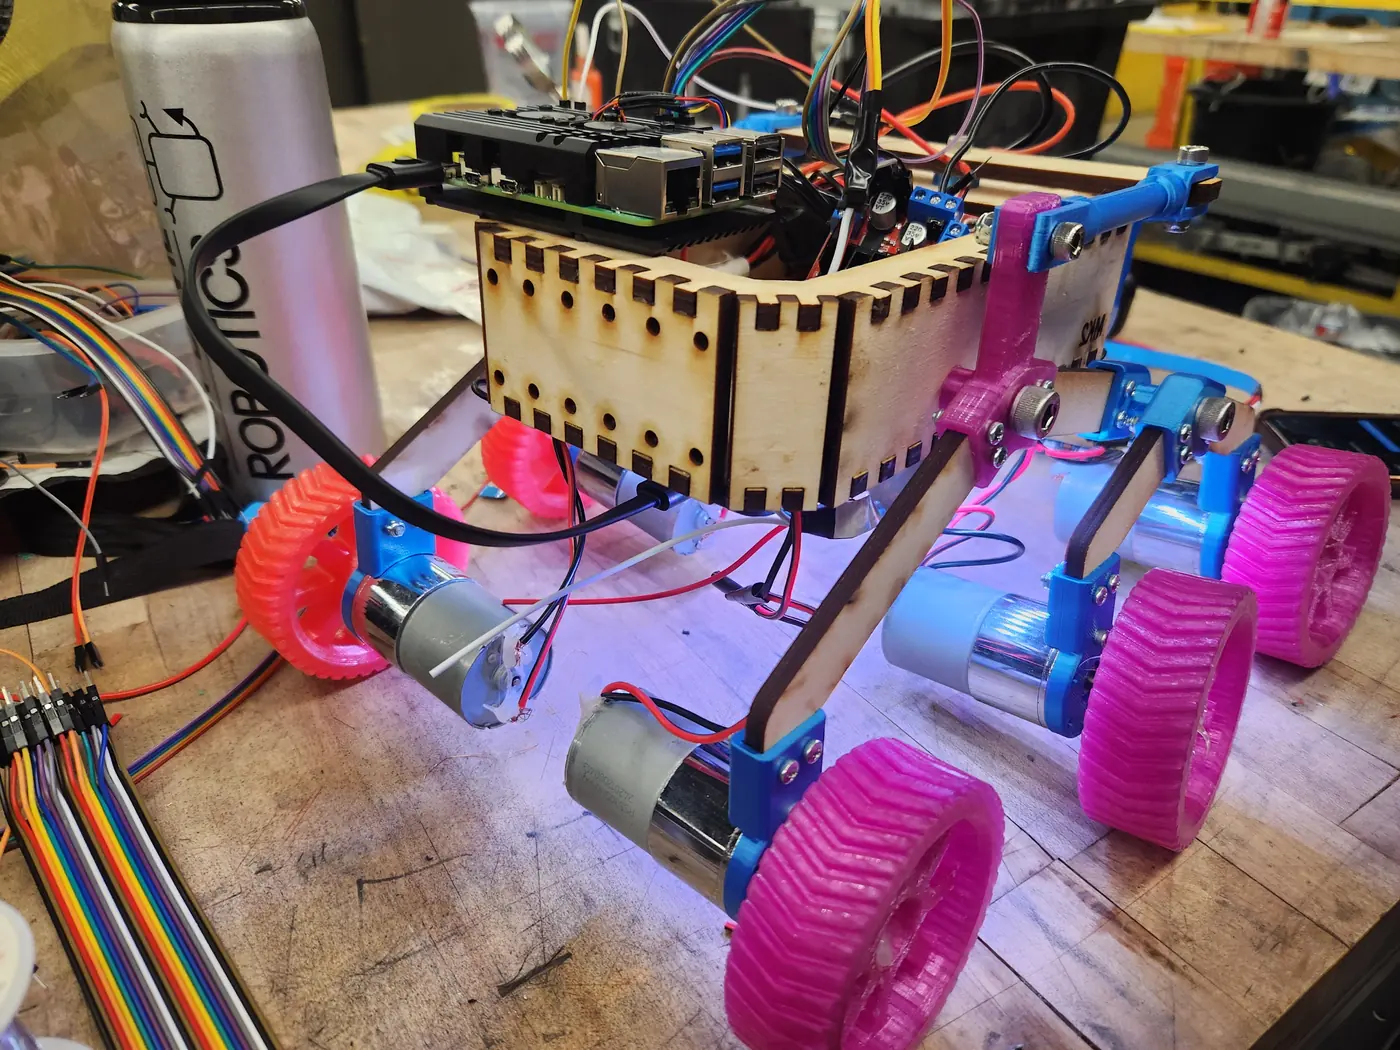
  • Designed the platform's Raspberry Pi 5 HAT in KiCad, from schematic capture and component selection through PCB layout and fabrication-ready manufacturing files.
  • Wrote the embedded Python firmware handling motor control, I2C sensor integration, and autonomous behavior logic.
  • Ran deployment workshops with 40+ interdisciplinary students, wrote the build documentation they assembled from independently, and turned their feedback into hardware revisions that cut part count and improved assembly repeatability.
RoleProduct Design Lead
ScopeThree generations · 40+ student builders
Years2023 – 2026
ToolsSolidWorks · KiCad · Raspberry Pi 5 · Python · DFA
NOMAD MK3, the final generation of the rover platform
MK3 — “Norm”
NOMAD MK1 prototype
MK1
NOMAD MK2 prototype
MK2
NOMAD electronics during integration
Integration
Senior Capstone

Invasive Species Removal Robot

Pull invasive plants in the field without herbicide, on a student budget and a two-semester schedule.

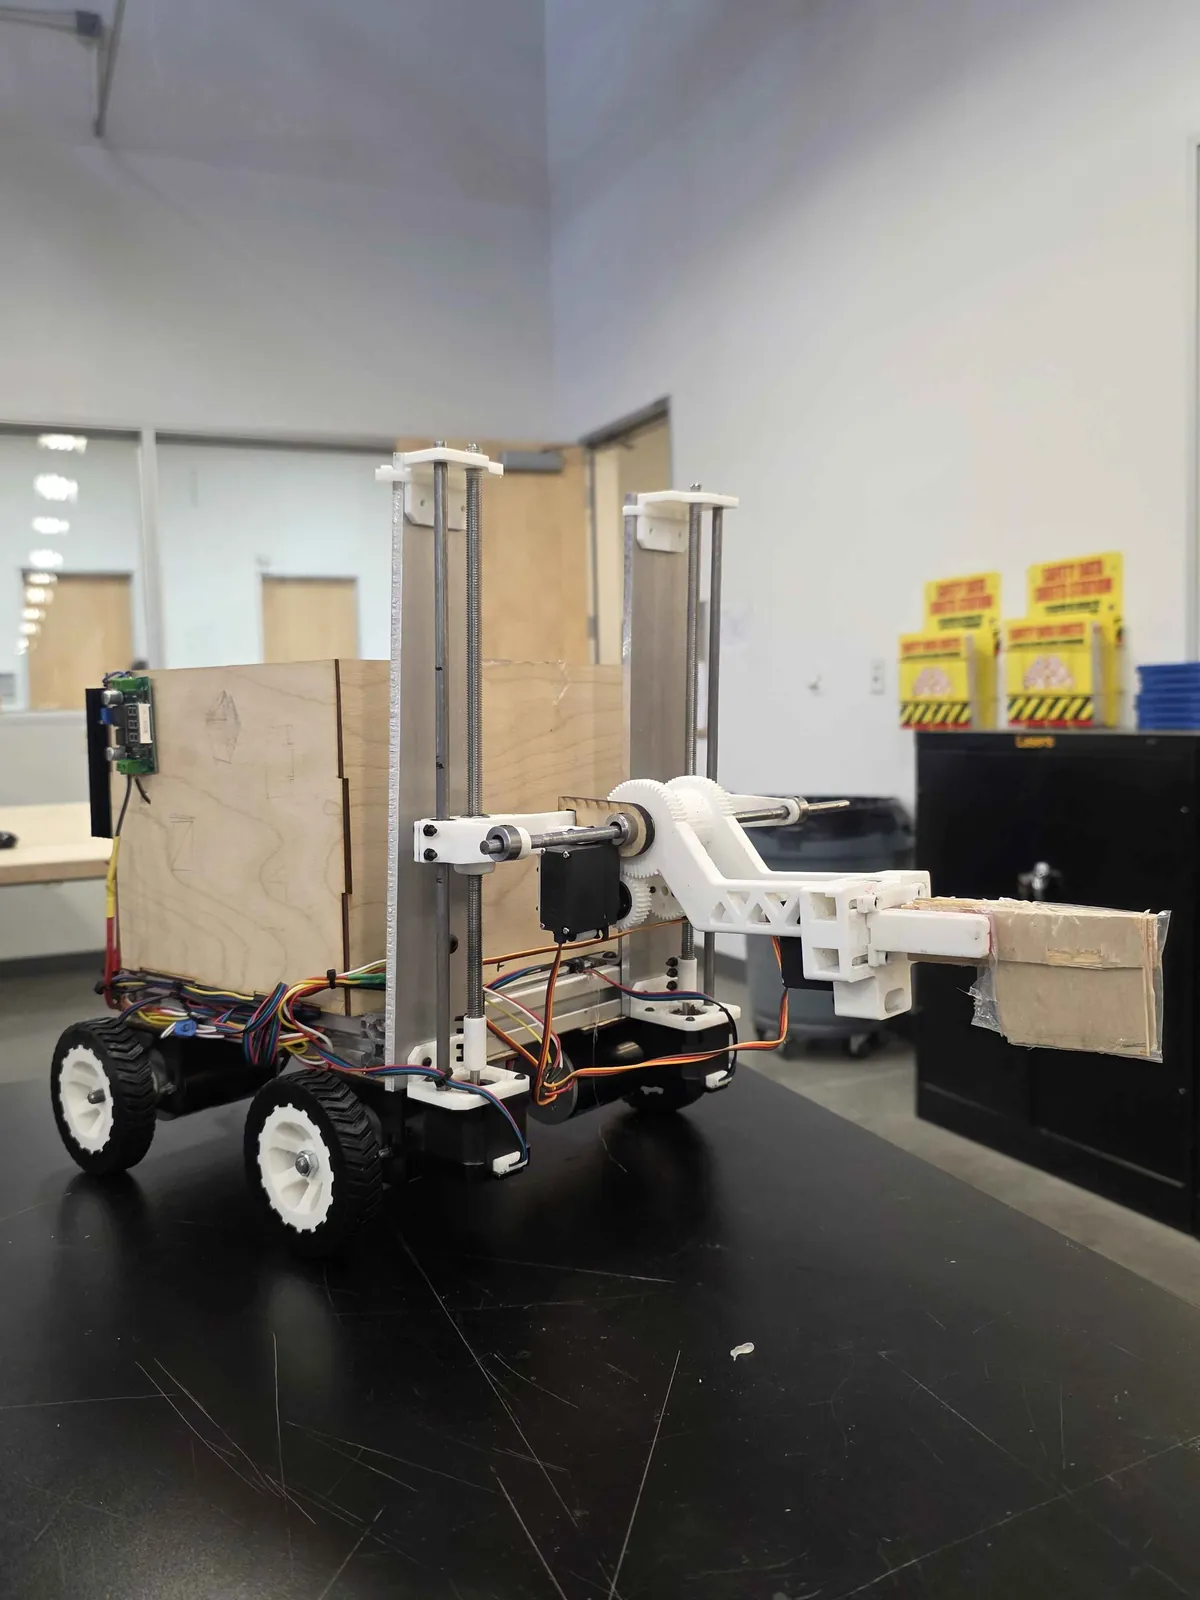
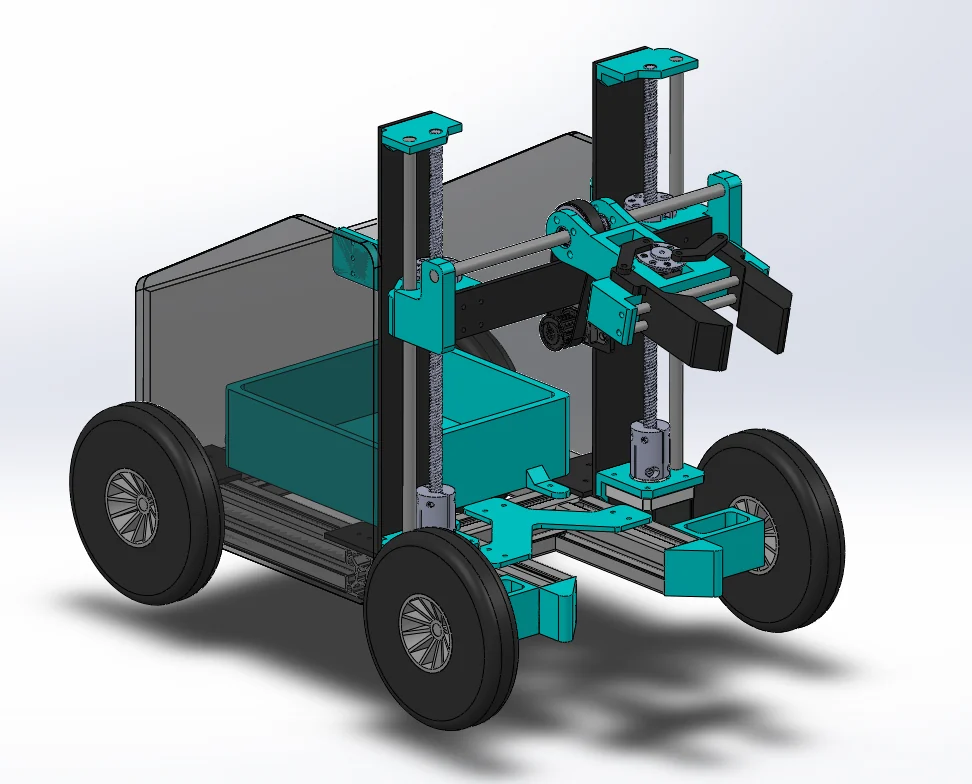
  • Led mechanical design and build of a teleoperated field robot on an eight-person team — chassis, collection system, arm, and gripper — from early requirements through fabrication, assembly, and system testing.
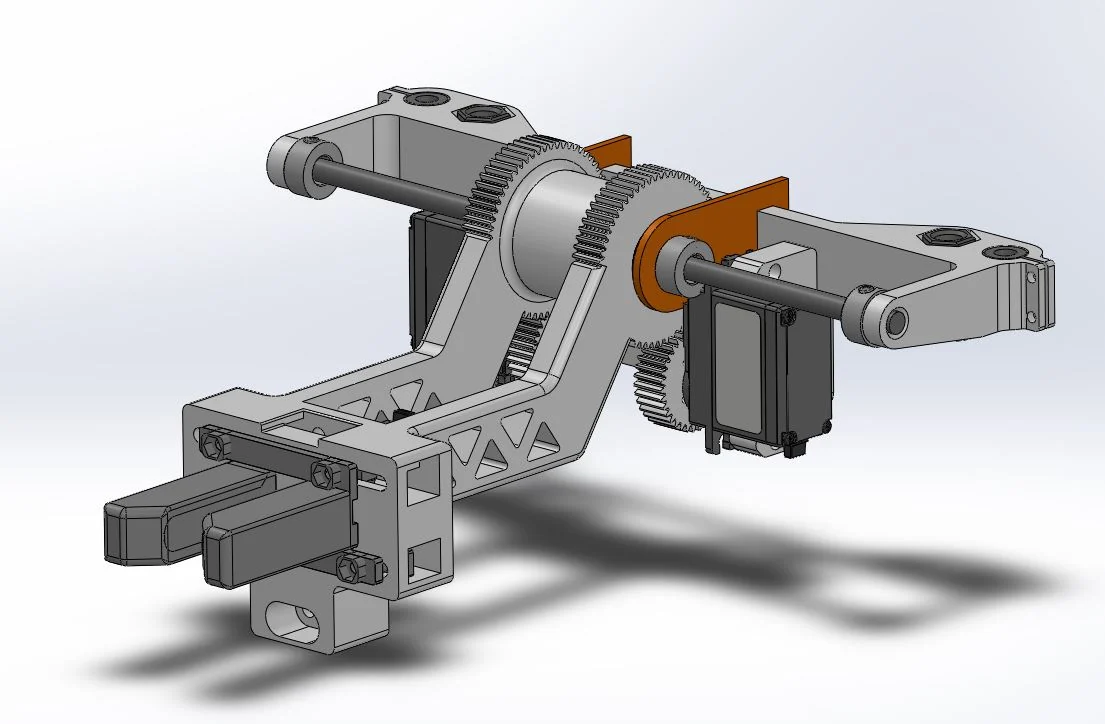
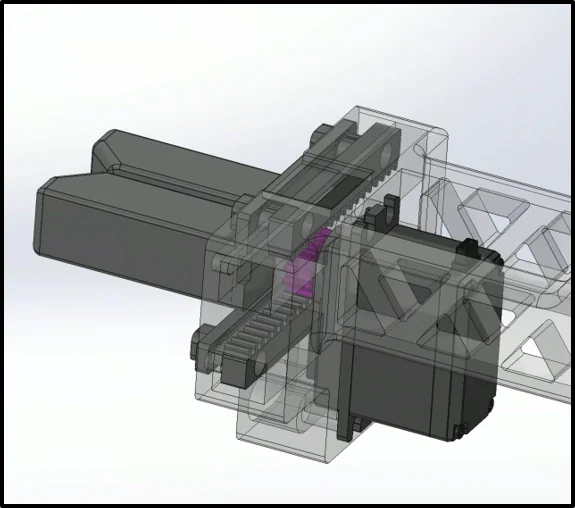
  • Sized the rack-and-pinion jaw mechanism against required grip force, selecting gear ratio and servo stall torque with margin, then set tolerances on nested printed components so mating gear teeth held fit across print runs.
  • Fabricated across machined aluminum, sheet metal, laser-cut parts, and FDM printing, selecting each method by geometry, tolerance, cost, and lead time.
  • Built dedicated test stands per subsystem, defined test procedures with the faculty advisor, then ran root cause analysis on recurring mounting-interface failures and revised until performance held.
RoleMechanical Design Lead
Team8 engineers
YearsAug 2025 – May 2026
ToolsSolidWorks · MasterCAM · CNC · Arduino
Assembled invasive species removal robot
Full robot CAD assembly
Assembly
Gripper mechanism CAD
Gripper
Gripper cutaway showing the internal gear train
Cutaway
Robotics Research

Cable-Driven Ankle Actuator

Deliver assistive torque at the ankle without the actuator fighting the wearer's own motion.

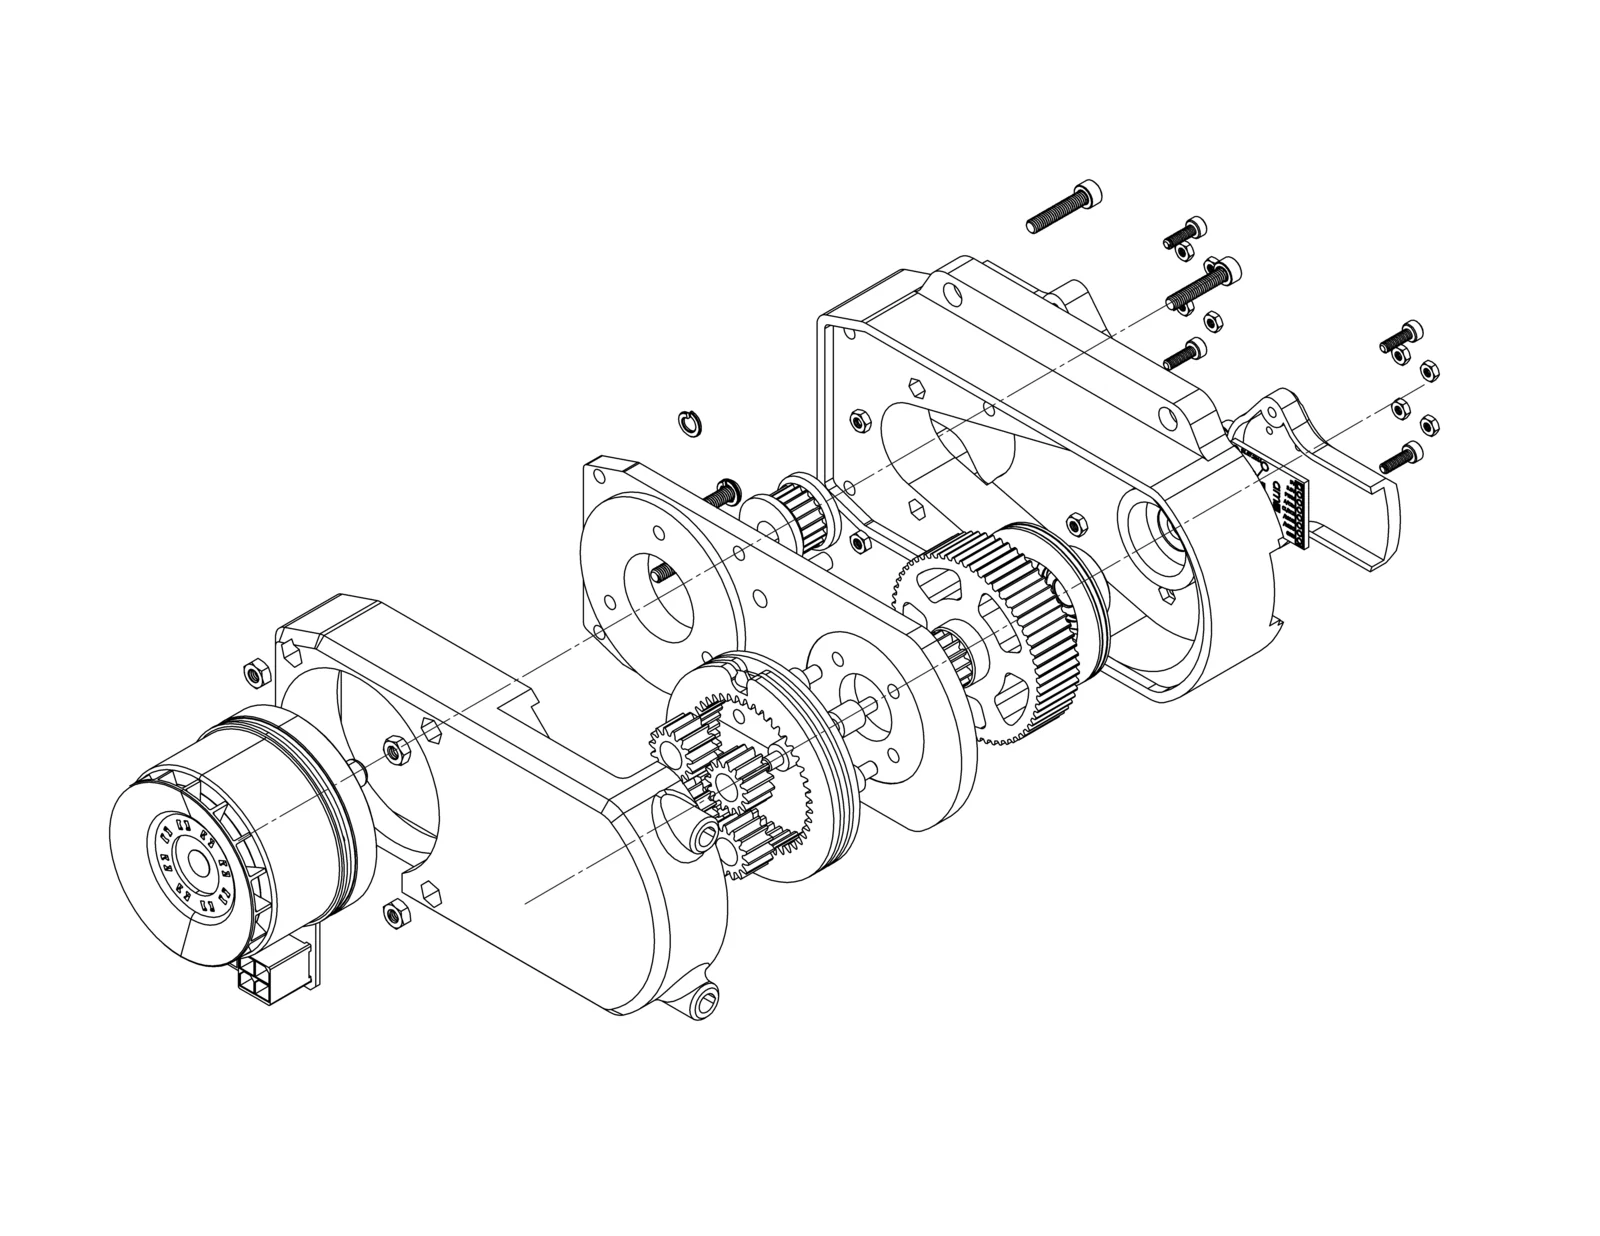
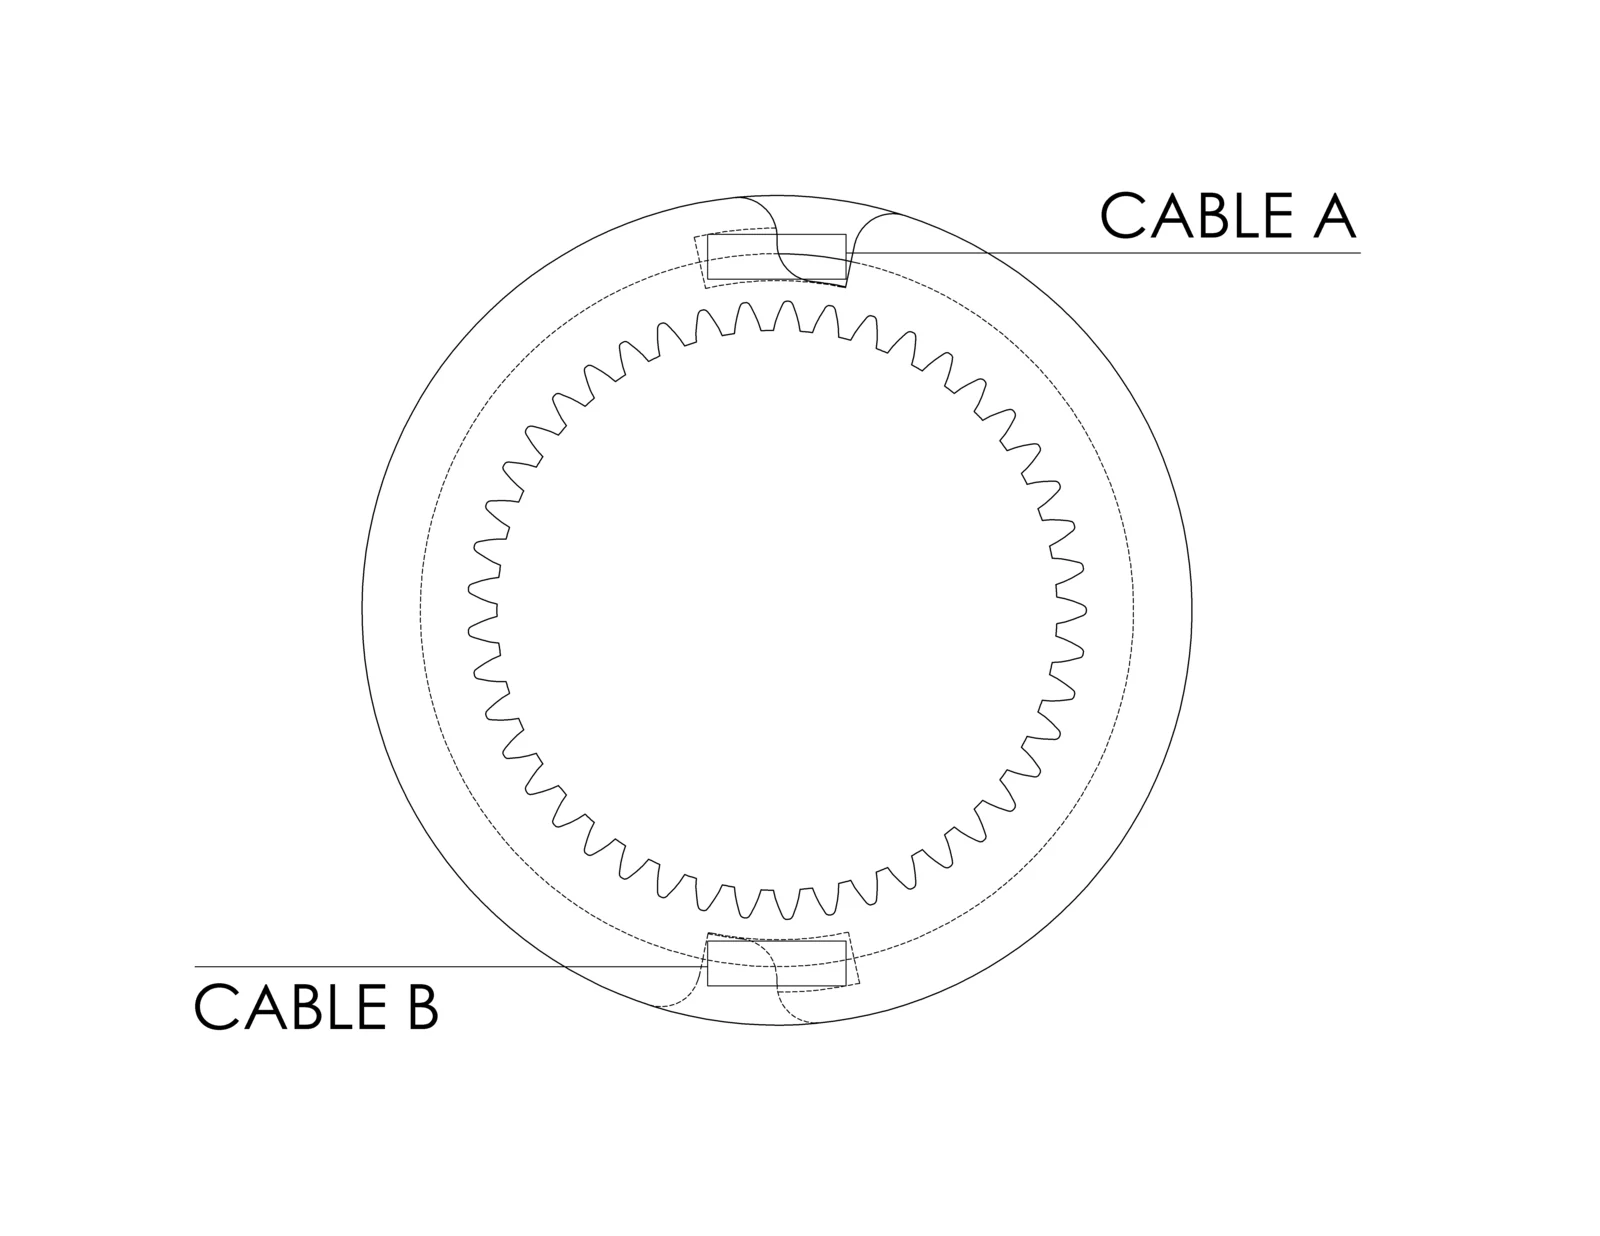
  • Designed and iterated cable-driven actuator assemblies for a wearable biomechanical device, developing motor, gear reduction, pulley, and cable-routing layouts for compact packaging and efficient force transmission.
  • Optimized packaging to preserve quasi-direct-drive behavior while balancing stiffness, manufacturability, and serviceability across prototype revisions.
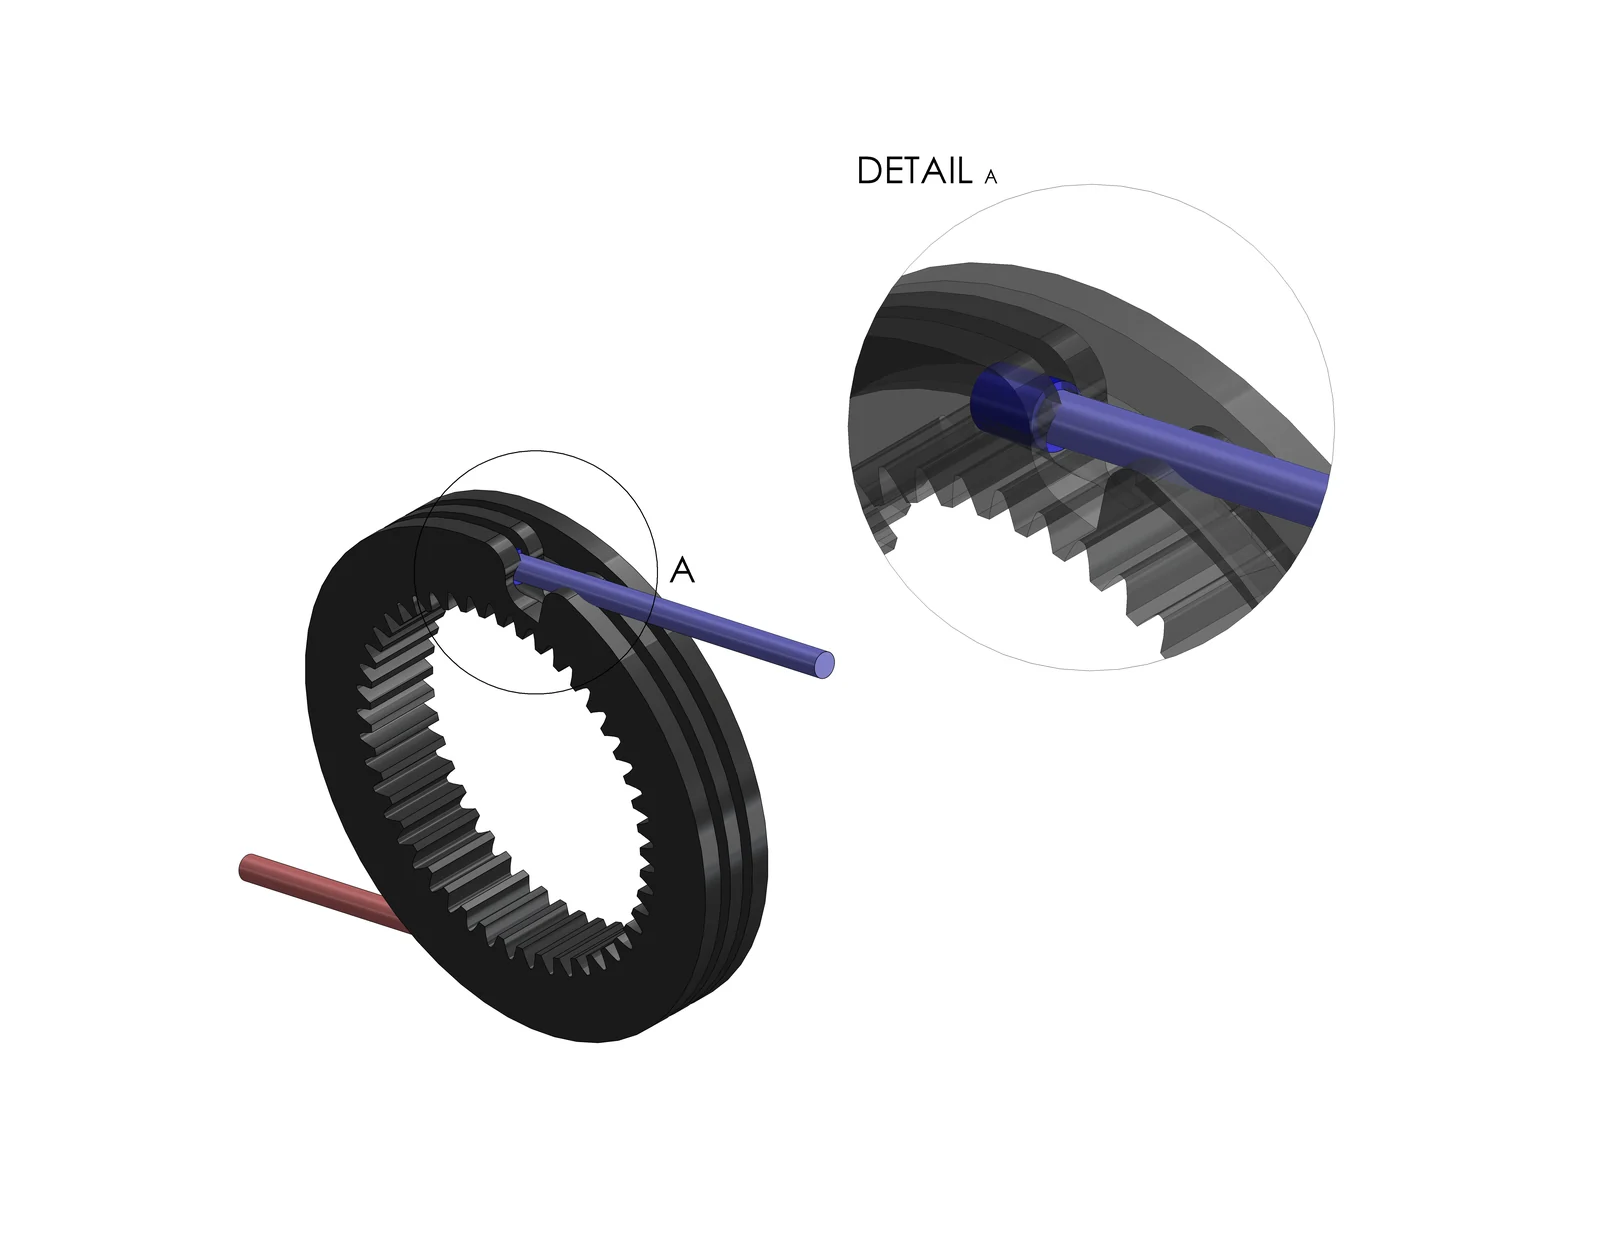
  • Characterized friction at the cable-pulley interfaces and traced backdrivability losses to surface residue left by printed supports — eliminating them through multi-material FDM and soluble-support experimentation.
  • Supported closed-loop torque control reaching roughly 5 Hz bandwidth, and prepared hardware for motion capture, EMG, and instrumented treadmill validation sessions.
RoleUndergraduate Researcher
LabASU Neuromuscular Control & Human Robotics
YearsMay 2024 – May 2025
ToolsSolidWorks · Cable-drive actuation · Multi-material FDM
Cable-driven actuator CAD assembly
Exploded actuator assembly
Exploded
Cable termination detail
Termination
Pulley cable routing drawing
Routing

Also built

Three more
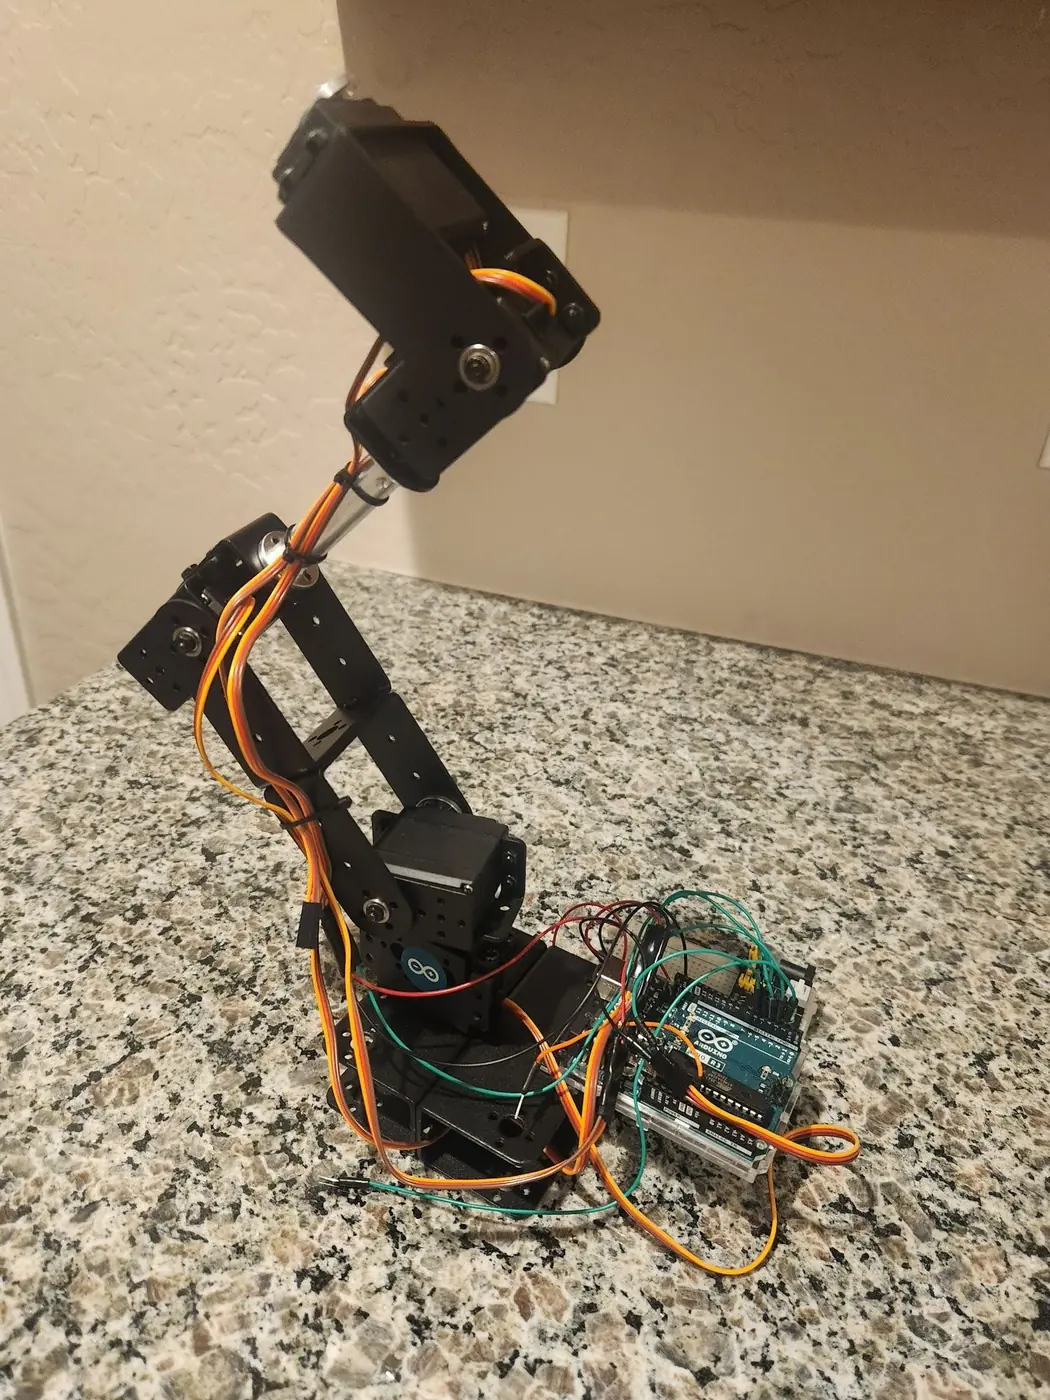
Multi-DOF robotic arm used in the inverse kinematics study
NASA Space Grant

Neural Network Inverse Kinematics

An independent, faculty-supported project testing whether a neural network can stand in for a conventional inverse-kinematics solver — and, more usefully, where it can't. Built and trained in MATLAB's Deep Learning Toolbox, benchmarked against conventional methods, with positional error mapped across the arm's full workspace. Presented at the 2024 Arizona Space Grant Consortium Conference.

MATLAB · Deep Learning Toolbox · Error analysis
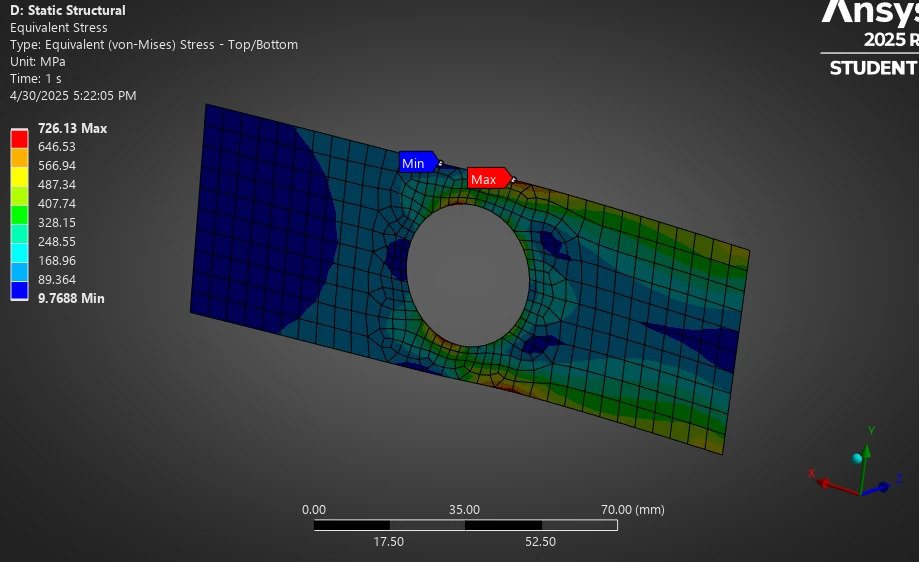
ANSYS von Mises stress result on a titanium plate with a central hole
Coursework · Spring 2025

FEA Solver Written From Scratch

A 2D plane-stress finite element solver built in MATLAB across four element types, derived from the weak form. Validated against ANSYS on identical geometry: 695 MPa peak von Mises vs 706 MPa, within 3%. A convergence study across eight mesh densities traced non-convergence of the domain maximum to a stress singularity at the fixed-edge corner — where no refinement produces a bounded result.

MATLAB · ANSYS Workbench · Gauss quadrature
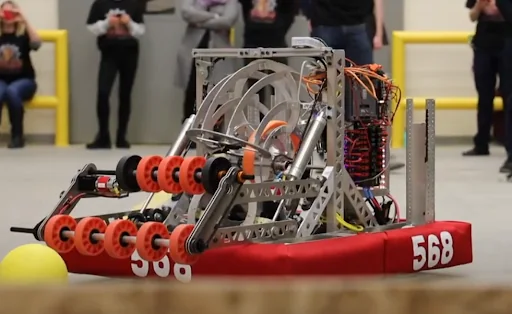
FRC team 568 robot on the competition field
2012 – 2022

FIRST Robotics — FLL 207, FTC 5223, FRC 568

A decade of competitive robotics out of Alaska, representing the state at the FIRST World Championship four times in build roles of increasing responsibility. Intake, scoring, and drivetrain mechanisms designed, machined, and repaired on the fly under build-season deadlines — where I learned that a design is only as good as the person who has to assemble it at 2am.

CNC machining · Sheet metal · Hands-on assembly

Path

2012 – present
2012 – 2022

FIRST Robotics — FLL #207, FTC #5223, FRC #568

Alaska · Four-time FIRST World Championship competitor

Aug 2023 – May 2026

President & Lead Mechanical Engineer

Sun Devil Robotics Club, Arizona State University

Aug 2023 – May 2024

Research Intern

ASU / NASA Space Grant Consortium

Oct 2023 – May 2025

3D Print Lab Aide

Ira A. Fulton Schools of Engineering, ASU · 12 FDM printers, 4 laser cutters

May – Jul 2024

Summer Research Intern

National University of Singapore · Mechanoluminescent materials characterization

May 2024 – May 2025

Undergraduate Researcher

Neuromuscular Control & Human Robotics Laboratory, ASU

Jun – Sep 2025

Custom Headlight Assembly Technician

RGB Halo Kits, Phoenix, AZ

Aug 2025 – May 2026

Mechanical Design Lead, Senior Capstone

Ira A. Fulton Schools of Engineering, ASU

May 2026

B.S.E. Mechanical Engineering — Computational Mechanics

Arizona State University, Tempe

About

Who's behind the CAD
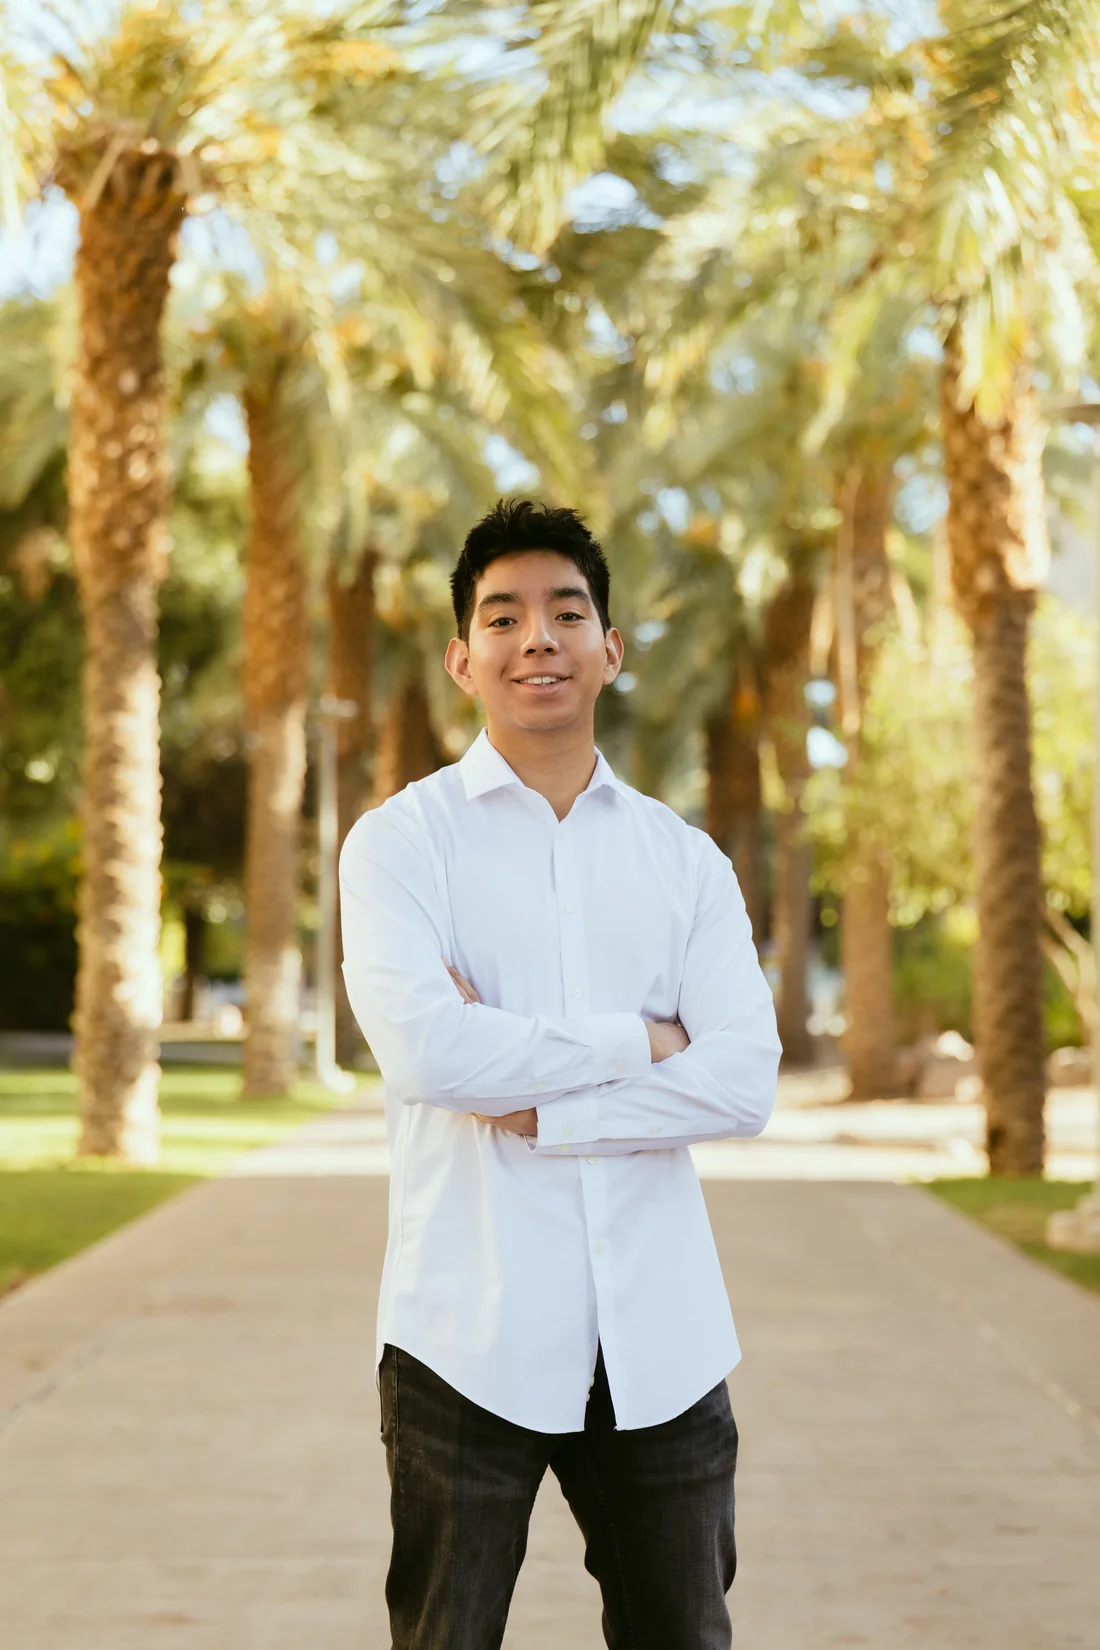
Mitchell Tecún

Guatemala → Alaska → Arizona

I'm Mitchell Tecún — pronounced tay-koon. I'm a mechanical engineer who'd rather have a part in hand than a rendering on a screen. I found my way into engineering through ten years of FIRST Robotics, which is where I learned that a design is only as good as the person who has to build it the night before a competition.

That's still how I work. At ASU I led a fifteen-person team through a full-scale Mars rover build, designed a cable-driven ankle actuator for a robotics lab, and spent two years running a print lab where I watched hundreds of student designs fail for the same handful of manufacturability reasons. Most of what I know about DFM I learned by fixing other people's parts.

I'm looking for a first role in mechanical design or electromechanical product development — somewhere I can own a subsystem from requirements through test, and still be in the shop the day it gets built.

B.S.E. Mechanical Engineering, ASU SolidWorks CSWA Certified Phoenix, Arizona Open to relocation

I’m ready to build.

I'm looking for a first full-time role in mechanical design or electromechanical product development. Based in Phoenix, open to relocation.